What
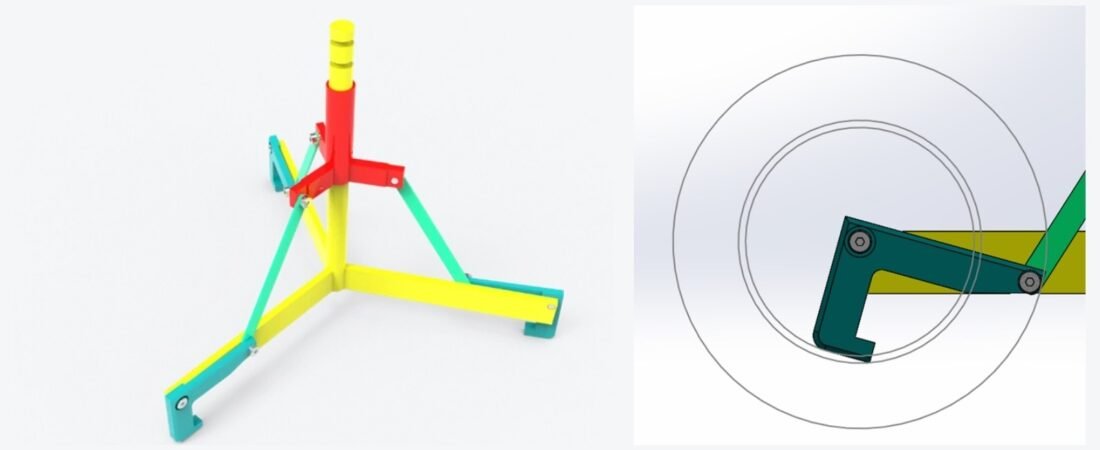
- Designed a proof-of-concept robotic claw to lift a 515 mm disc, 22 to 25 mm thick, from the top while it rests on a 50 mm platform.
- Met strict client requirements: minimal moving parts, easy manufacture, simple maintenance and operation from a single servo motor.
How
- Developed a mechanism that converts linear collar motion into circular claw movement, so the claws grip cleanly from above without striking the disc edge.
- Iterated through the constraints and adopted a three-claw, 120° layout for stability, clearance and reliable lifting.
- Modelled and assembled in SolidWorks for efficient parametric control of the geometry.
Results
- Delivered a functional claw with a 520 mm internal gripping diameter, giving the required 5 mm clearance for safe operation.
- Produced a validated proof of concept meeting every client criterion, with linear actuation intended to be driven by a screw jack.
Tools and processes: SolidWorks, mechanism design, linkage kinematics, clearance analysis, servo actuation