What
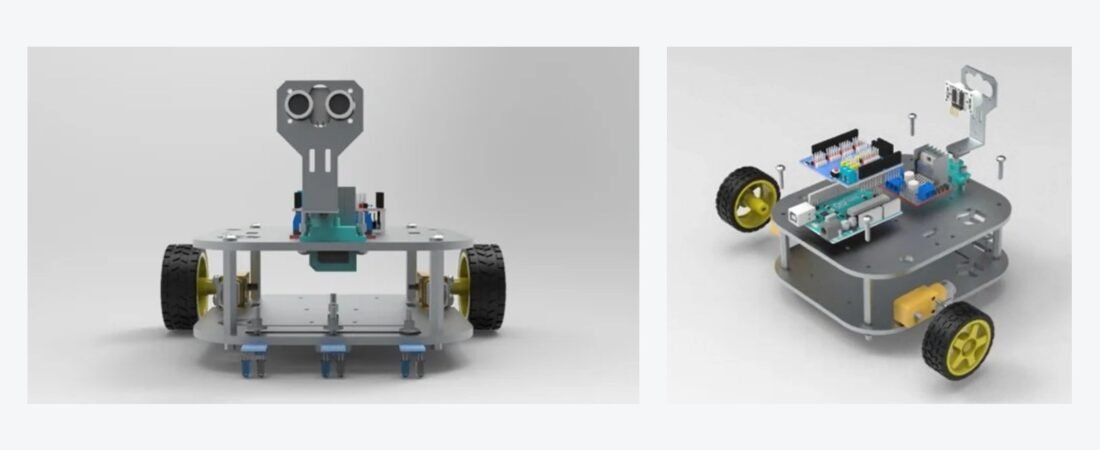
- Designed and fabricated a sonar-based line follower robot with obstacle avoidance as an internship project at Usman Engineering, leading an interdisciplinary team.
- Aimed for a simple, low-cost educational robot built with in-house manufacturing and easily sourced components.
How
- Modelled the robot in Creo Parametric, choosing simple mechanisms such as a metal ball caster for free steering, with IR sensors, sonar and a servo for navigation.
- Integrated all systems into a bi-plate metal chassis for easy assembly and room for future upgrades.
Results
- Delivered a fully functional robot that met all requirements.
- Produced an exploded-view animation to communicate the assembly.
Tools and processes: Creo Parametric, sheet metal chassis fabrication, IR and ultrasonic sensing, servo control, team leadership